
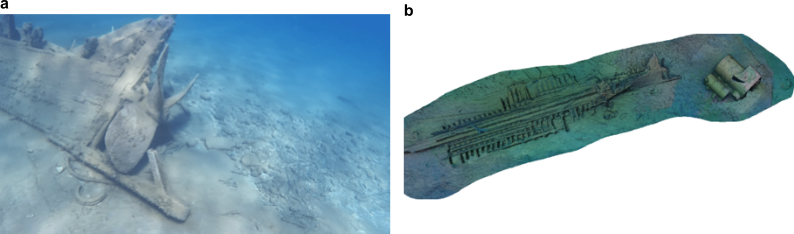
Autonomous marine robots face significant perception challenges due to poor underwater visibility, changing illumination, and complex environmental conditions. Our research investigates multimodal perception and vision-based navigation architectures that leverage RGB cameras, sonar, and event-based sensors to enhance environmental awareness, autonomous operations, and improved environmental knowledge. We explore attention-driven perception, target tracking and interaction, underwater anomaly detection, and environmental observation focused on spiking neural networks to process event-based data. Through the development and evaluation of these approaches on marine robotic platforms, we aim to improve the robustness and reliability of perception and navigation in challenging aquatic environments.
These projects have been funded by the National Science Foundation, National Oceanographic Atmospheric Administration, and Coastal Protection and Restoration Agency